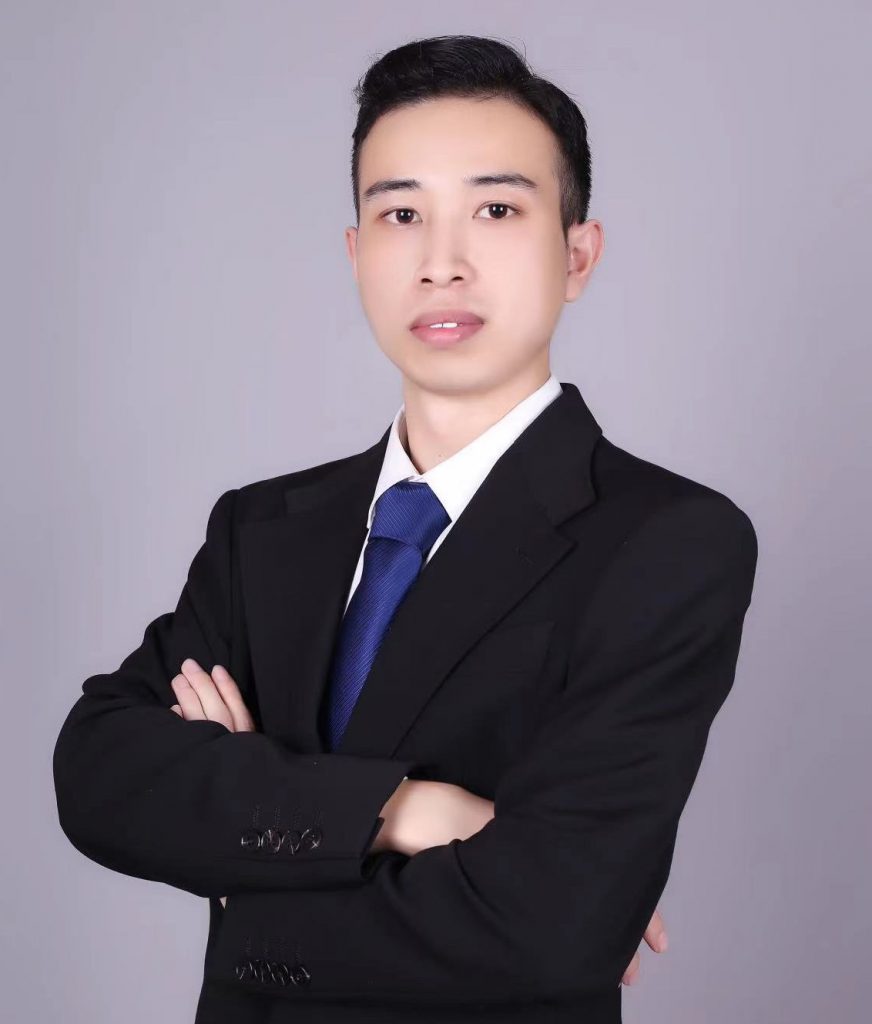
Haolin (Harry) Zhang
Ph.D. Candidate
Institute of Artificial Intelligence and Robotics
College of Artificial Intelligence, Xi'an Jiaotong University
Research Interests
I am a Ph.D. candidate at Xi'an Jiaotong University, working on autonomous driving perception, V2X cooperative intelligence, and computer vision. My research focuses on building robust 3D perception systems for intelligent vehicles and roadside infrastructure.
News
- 2025.02 One paper accepted by IEEE T-ITS on anchor-based LiDAR 3D detection
- 2024.12 "3D Harmonic Loss" accepted by IEEE T-VT
- 2024.11 Won First Prize at the 14th China Intelligent Vehicle Future Challenge (Captain)
- 2024.10 Received Xi'an Jiaotong University Outstanding Graduate Student Award
- 2023.09 Started Ph.D. at Xi'an Jiaotong University, College of Artificial Intelligence
- 2022.06 "Pedestrian Crossing Intention" paper selected as T-IV Best Paper (2020–2023)
Education
Ph.D. in Artificial Intelligence
Research: Autonomous driving, computer vision, V2X cooperative perception, and intelligent transportation systems.
M.S. in Electrical & Computer Engineering
GPA: 3.78/4.0. Research on pedestrian crossing intention prediction using spatio-temporal attention. Advisor: Prof. Keith Redmill & Prof. Ümit Özgüner.
B.E. in Electronic Information Engineering
GPA: 3.8/4.0 (Ranked 1st). Shanghai Outstanding Graduate (2019).
Experience
Research Project Lead
Leading research on roadside cooperative perception systems. Designed monocular 3D detection and tracking using ground-plane constraints (average localization error ~0.4m within 50m). Developed semi-automated multi-sensor calibration and 4D annotation toolkits. Systems deployed in Beijing E-Town and Hangzhou.
Research Engineer
Contributed to documentation, lab co-construction, research project organization, engineering development, and competition preparation. Guided junior students and drove autonomous driving perception deployment.
Technical Partner & CV Engineer
Led computer vision projects and project management. Built AI kitchen surveillance (deployed at Hangzhou highway service stations), pen-tip defect detection (99.8% accuracy, patent granted), and AI-powered smart scale with incremental learning (mass-produced and commercialized).
Algorithm Engineer
Developed perception algorithms and toolchains for Leapmotor's intelligent driving system. Built semi-automated annotation/evaluation platforms for 2D detection, keypoints, orientation, and instance segmentation. Designed fine-grained vehicle classification and traffic sign recognition models for C11 NOA system.
Honors & Awards
- 2024 Xi'an Jiaotong University — Outstanding Graduate Student
- 2024 14th China Intelligent Vehicle Future Challenge — First Prize (Captain)
- 2024 China Mobile 8th Maker Marathon National Finals — Maker Pioneer Award
- 2024 XJTU–China Mobile Digital Government Joint Institute — First Prize
- 2023 13th China Intelligent Vehicle Future Challenge — First Prize (Team Member)
- 2022 China (Zibo) Connected Intelligent Vehicle Challenge — First Prize
- 2021 Huaruijie — Outstanding New Employee of the Year
- 2019 Shanghai Outstanding Graduate